Overview
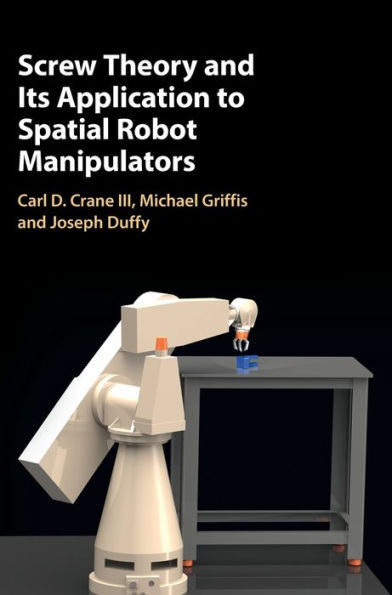
Discover a fresh take on classical screw theory and understand the geometry embedded within robots and mechanisms with this essential text. The book begins with a geometrical study of points, lines, and planes and slowly takes the reader toward a mastery of screw theory with some cutting-edge results, all while using only basic linear algebra and ordinary vectors. It features a discussion of the geometry of parallel and serial robot manipulators, in addition to the reciprocity of screws and a singularity study. All 41 essential screw systems are unveiled, establishing the possible freedom twists and constraint wrenches for a kinematic joint. Familiarizing the reader with screw geometry in order to study the statics and kinematics of robots and mechanisms, this is a perfect resource for engineers and graduate students.
- | Author: Carl D., III Crane
- | Publisher: Cambridge University Press
- | Publication Date: Sep 15, 2022
- | Number of Pages: 238 pages
- | Binding: Hardback or Cased Book
- | ISBN-10: 0521630894
- | ISBN-13: 9780521630894